Week 32 – Retraining
This week goal was to free the arms from the network control. In order to do that, I firstly try to traing it leaving the elbows “dead”.
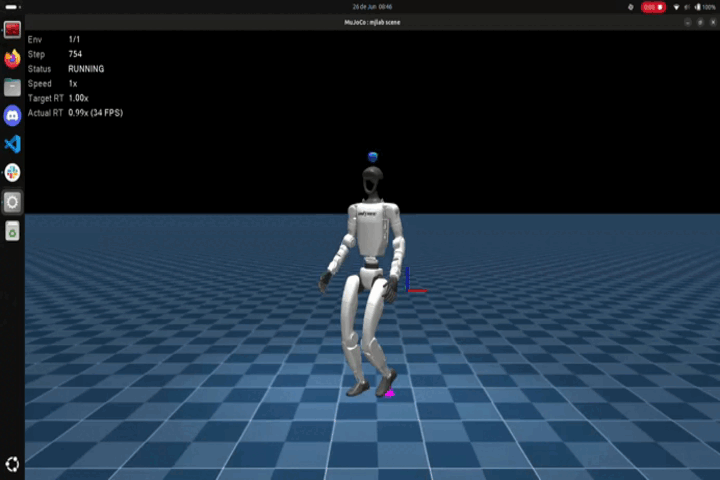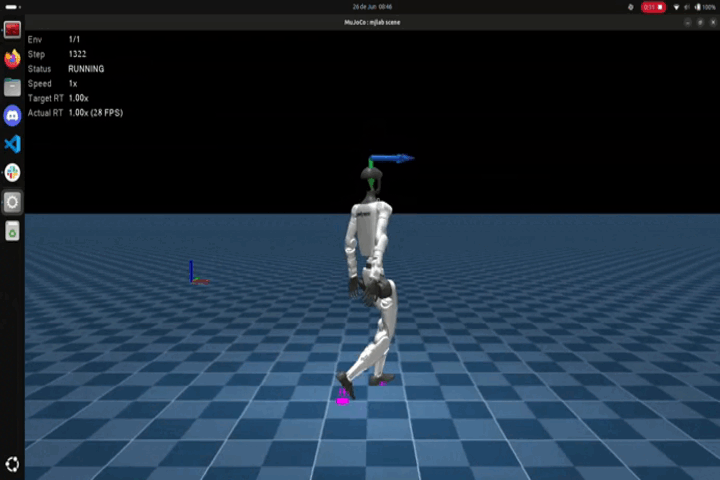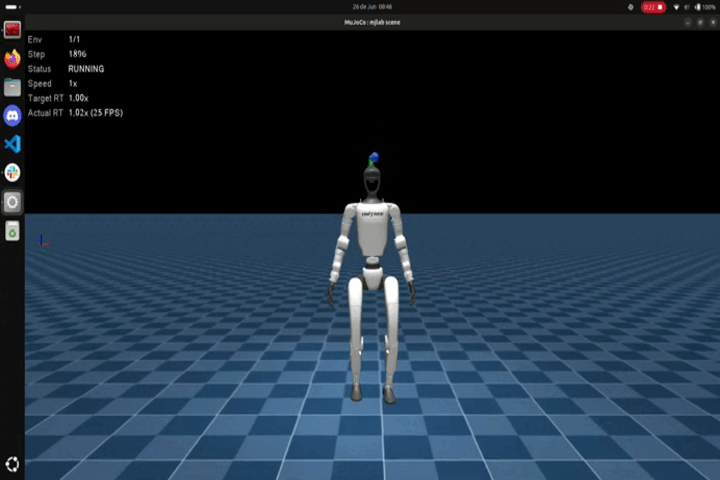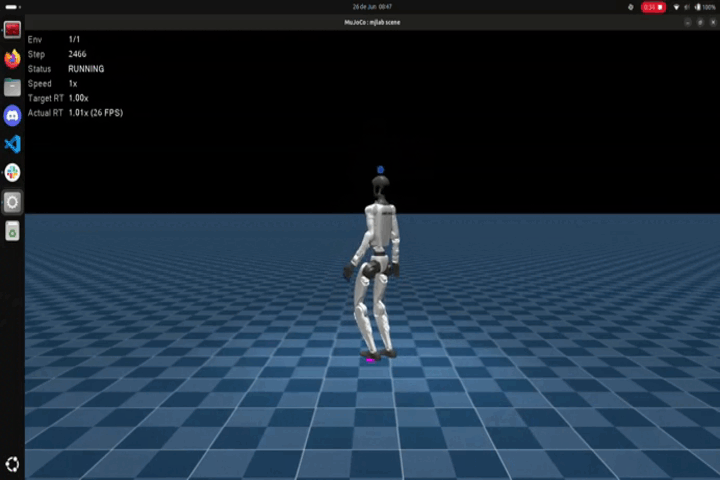
The training was succesfull, obtaining this result.
Next week I’ll be working on keeping the elbows in place and then making the robot able to move while I move them.
Summary
- Training the network to not use the elbows